Project overview
This project develops a practical RGB-event acquisition pipeline for camera combinations that cannot share a hardware trigger. A Prophesee EVK4 and a Basler acA1300-60gmNIR observe the same optical path through a 50/50 beam splitter, while host-clock mapping and packet-level timestamp anchoring align their streams on an NVIDIA Jetson AGX Orin mounted to a Unitree Go2.
Core contributions
- A coaxial beam-splitter rig that removes parallax by construction and uses pitch-ratio normalization plus one-time residual-offset calibration.
- A robust global affine mapping from each camera clock to the host timeline, explicitly accounting for clock offset and drift.
- A local per-packet anchoring method implemented in a ROS 2 acquisition pipeline for drift-independent event timing.
- Frame-centered event windows, event rendering, YOLO detections, tracking identities, and annotation transfer for multimodal dataset generation.
Current evidence
The reported calibration used 90 accepted image pairs and 4,860 correspondences, with a 100% RANSAC inlier ratio. The results support sub-millisecond temporal alignment and sub-pixel spatial registration for frame-to-event label transfer.
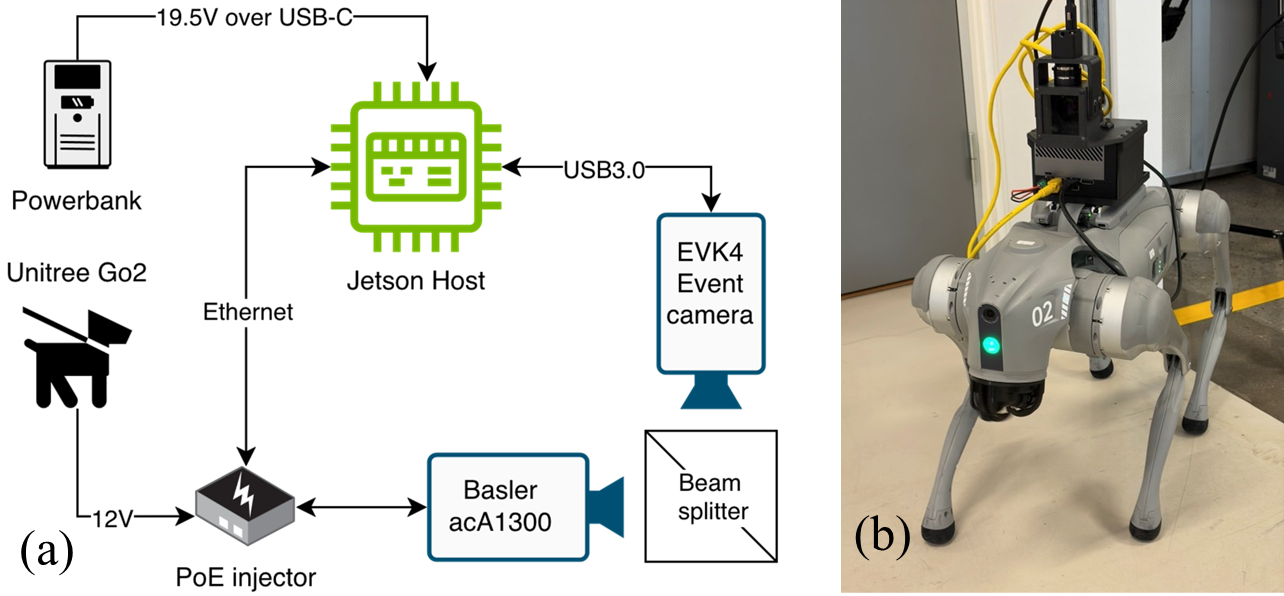
System and deployment
- Prophesee EVK4 event camera and Basler acA1300-60gmNIR monochrome frame camera.
- Matched optics behind a 50/50 non-polarizing beam splitter.
- NVIDIA Jetson AGX Orin and ROS 2 on a Unitree Go2 mobile robotic platform.
Why it matters for robotics
Accurate cross-modal alignment lets mature RGB annotation and tracking tools supervise event data. That makes it possible to build mobile-robot datasets for human detection, tracking, segmentation, and interaction without manually labeling sparse event streams.